|
Sungil Son I'm a PhD student in the Interdisciplinary Program in Artificial Intelligence at Seoul National University, working at Lab for Autonomous Robotics Research (LARR) under the guidance of Prof. H. Jin Kim. |
|
News
|
Publications |
|
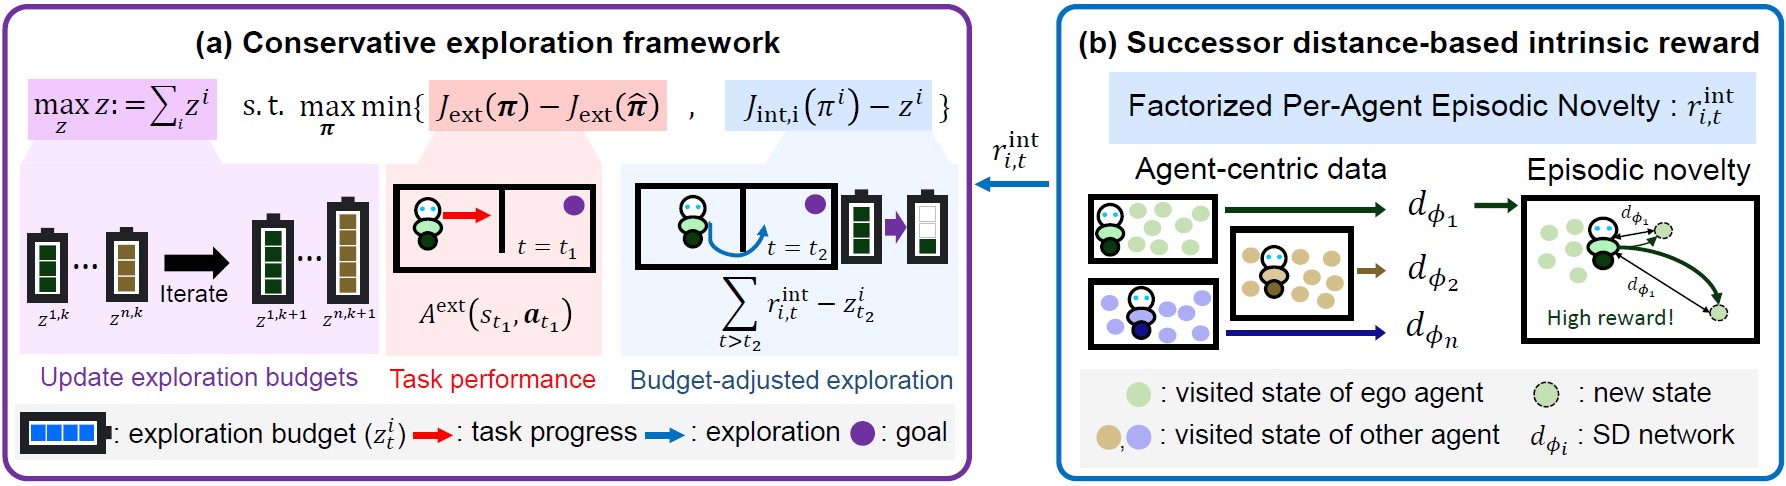
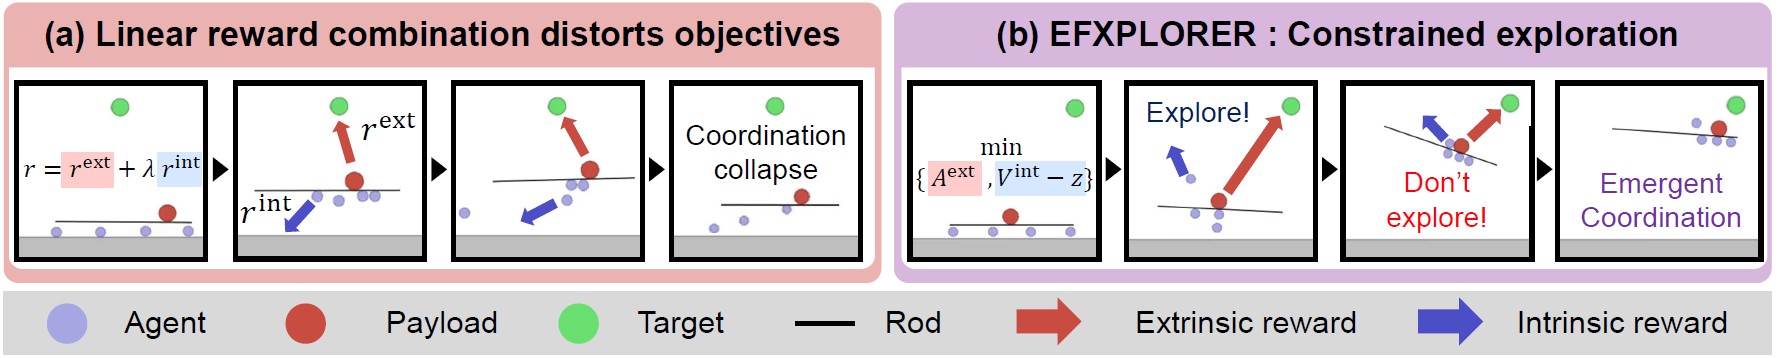
Cooperative Multi-Agent Reinforcement Learning via Epigraph-Form Guided Exploration
Sungil Son*, Hoseong Jung*, Dahyun Oh*, H. Jin Kim Seoul National University *Equal contribution NeurIPS, 2026
project page In this paper, we propose EFXPLORER, a constrained exploration framework that maximizes exploration objectives subject to a constraint that preserves established task performance. |
|
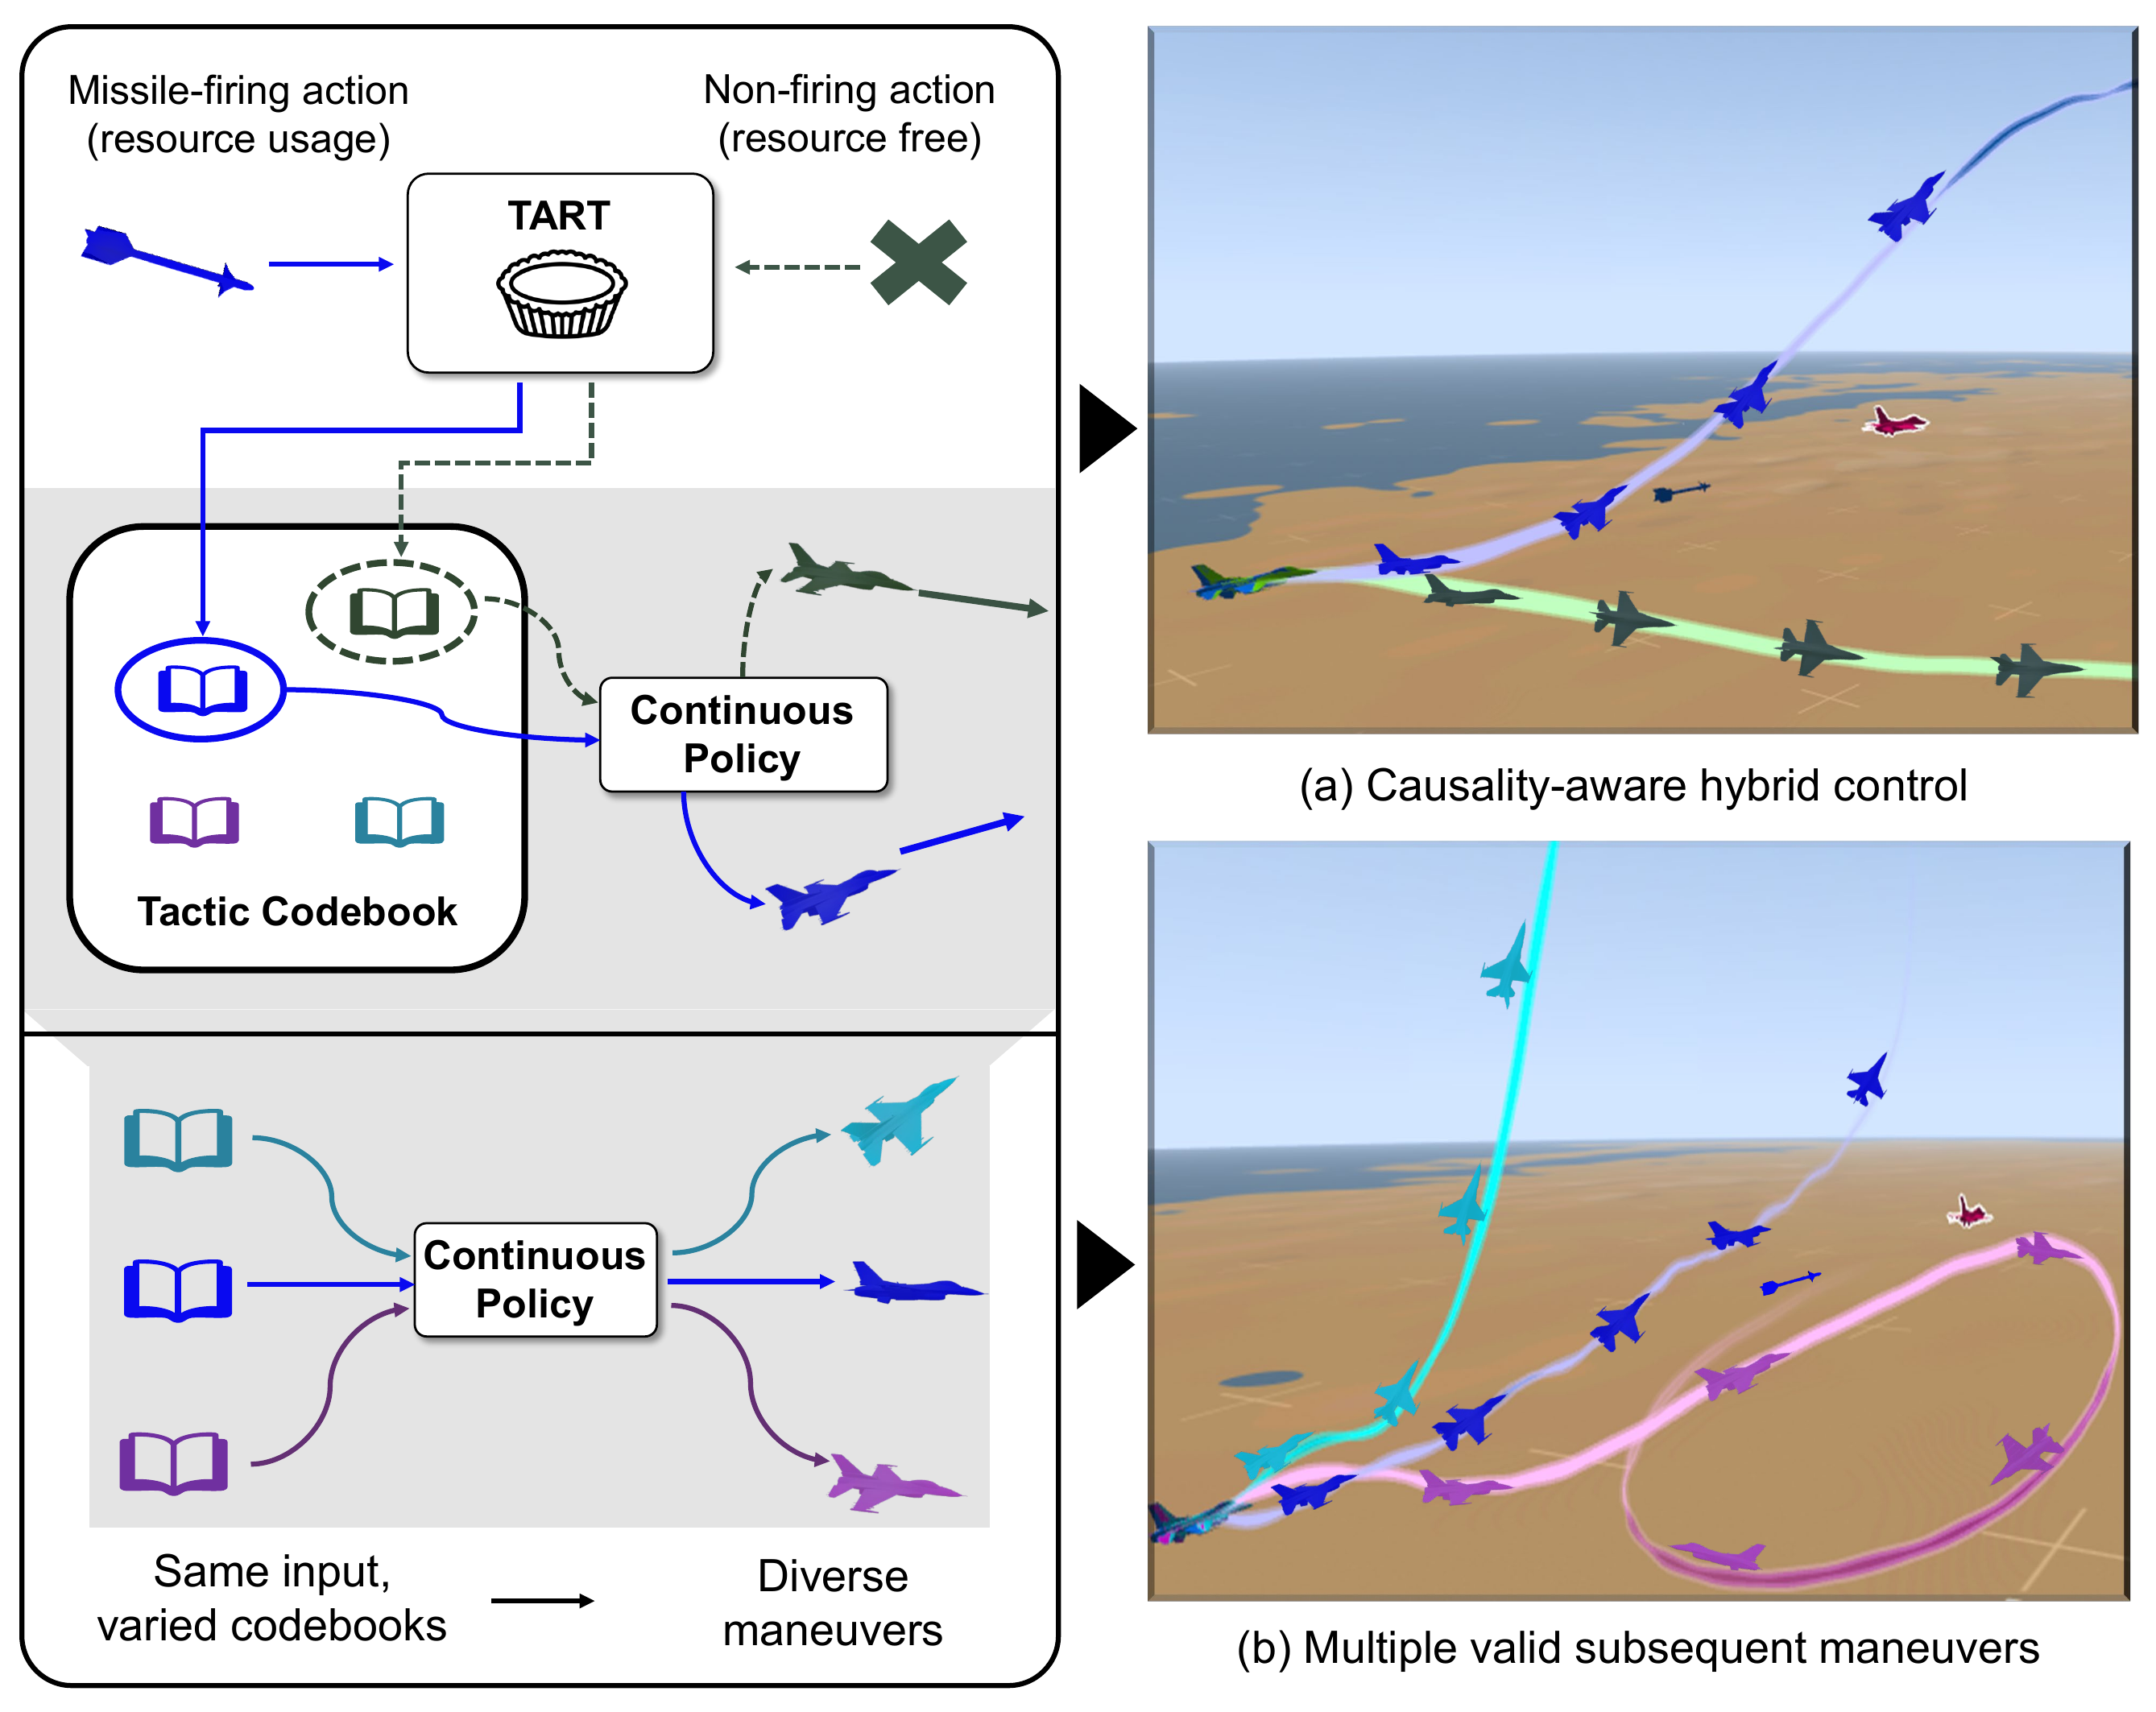
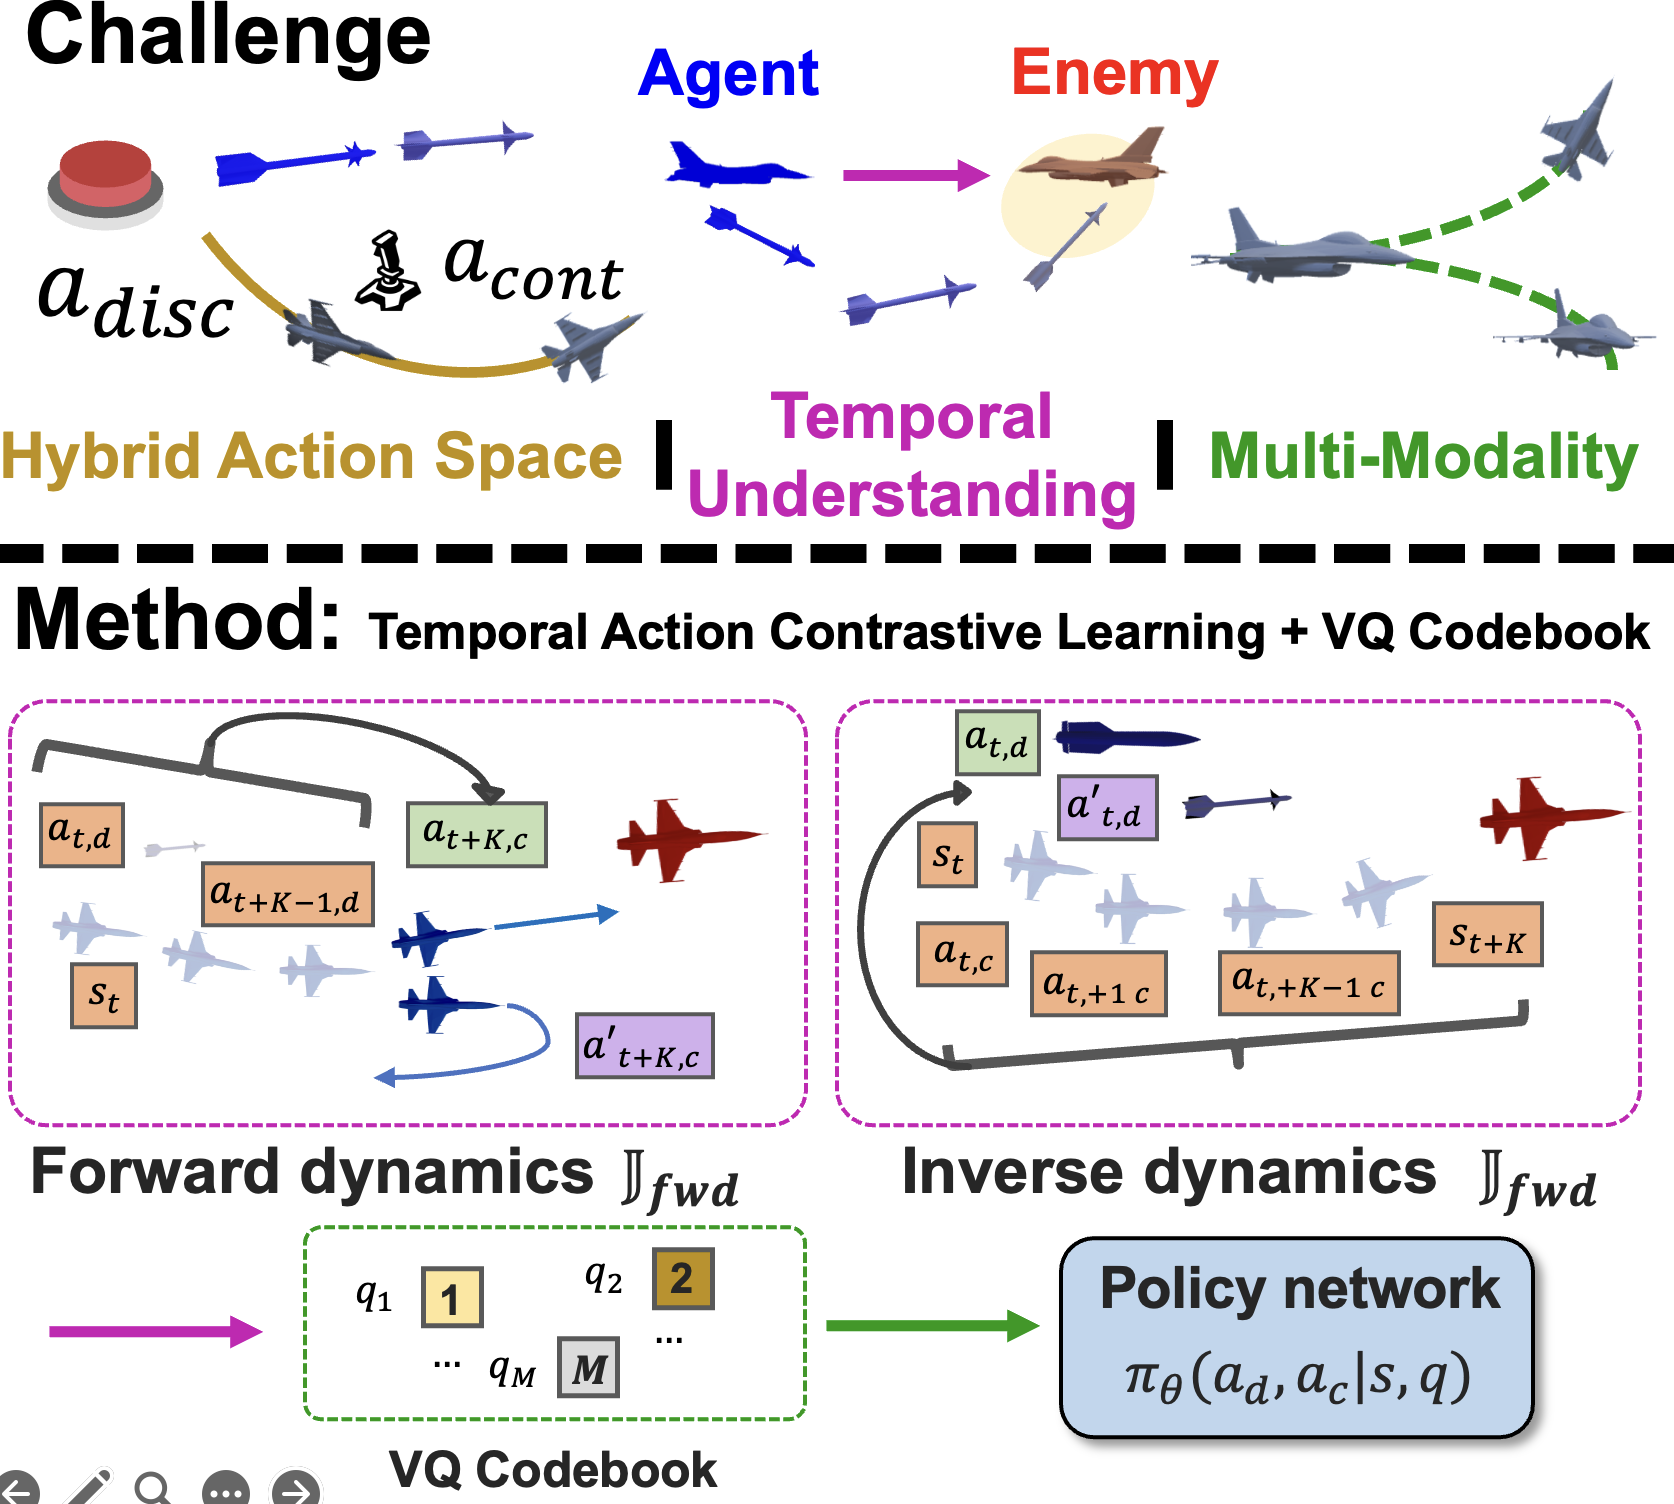
Temporal Action Representation Learning for Tactical Resource Control and Subsequent Maneuver Generation
Hoseong Jung, Sungil Son, Daesol Cho, Jonghae Park, Changhyun Choi, H. Jin Kim IEEE International Conference on Robotics and Automation (ICRA), 2026
RSS workshop on Leveraging Implicit Methods for Aerial Autonomy, 2025
paper / project page In this paper, we introduce a temporal action contrastive learning approach that facilitates semantic alignment between resource control and tactical maneuvers. |
Projects |
|
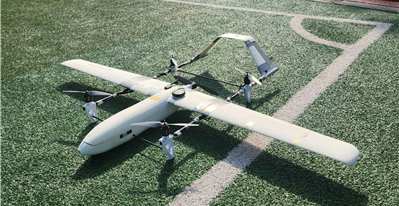
video / report (Korean) / report (English) |
||
|
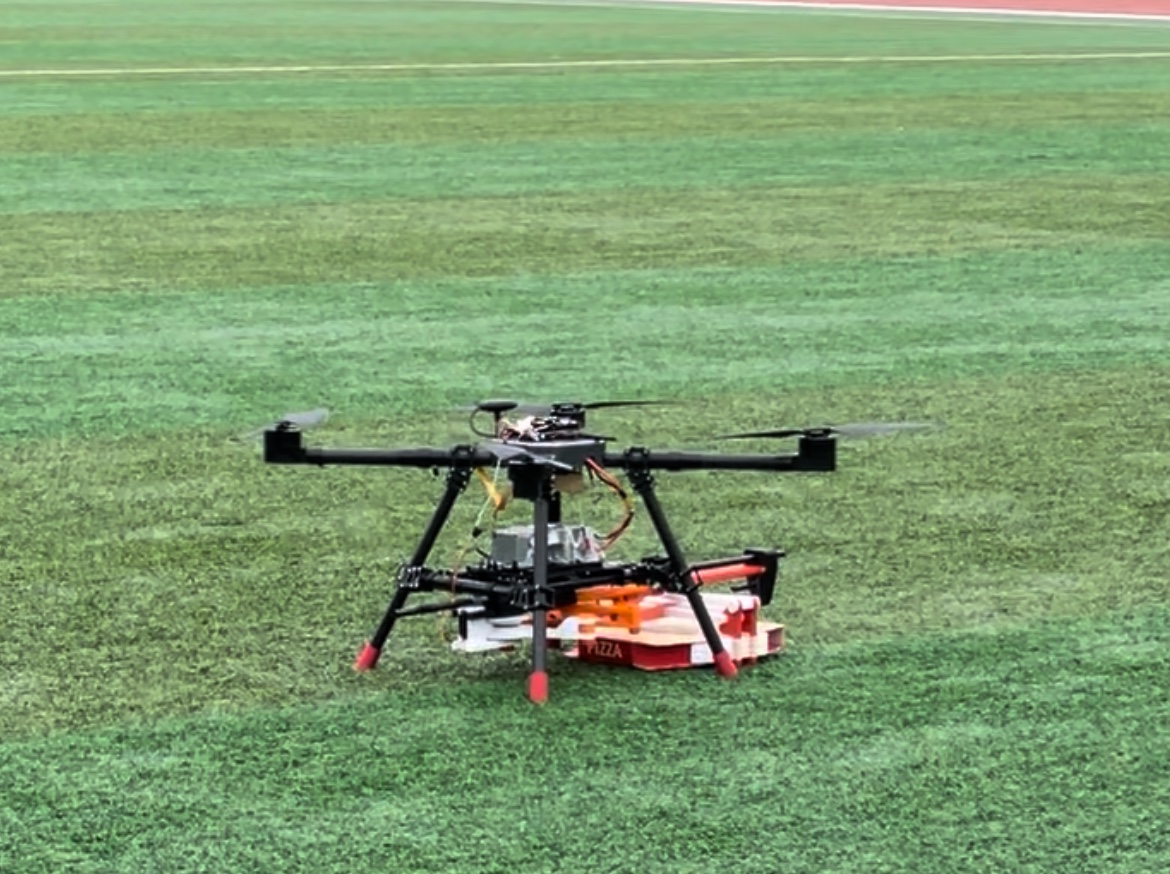
video / report (Korean) |
Awards
|
Education
|
|
Template from Jon Barron. |